Determining the d.o.f. count#
Grübler’s formula for planar mechanisms#
It is a systematic method to find out the number of d.o.f. of a mechanism.
With:
\(G\): Overall d.o.f. (the result we are looking for!).
\(N\): Number of links, including the ground.
\(p_{I}, p_{II}\): Number of degree I and degree II joints.
Formula discussion:
Each free planar body has 3 d.o.f.; hence, the \(N-1\) moving links have \(3(N-1)\) d.o.f. (the ground has none).
Each degree I joint (such as R or P) connecting two links removes 2 d.o.f.
Each degree II joint (such as a cam) connecting two links removes 1 d.o.f.
Kutzbach’s general formula#
Grübler’s formula is a special case of Kutzbach’s formula, which is more general and applies to both planar and spatial mechanisms.
For planar mechanisms: It is identical to Grübler’s.
For spatial mechanisms (3D):
where a free body in space has 6 d.o.f., and \(p_i\) is the number of joints allowing \(i\) degrees of freedom. For example, a revolute joint (\(p_1\)) removes 5 d.o.f.
Practical application of the formula#
Number all links: Ground is #1, etc.
Identify the kinematic pairs: Tell degree I from degree II joints.
Apply the formula: \(G=3(N-1) -2 p_{I} - p_{II}\)
Numbering options#
It is common to find more than one way to number links and joints, but they will eventually be equivalent. For example:
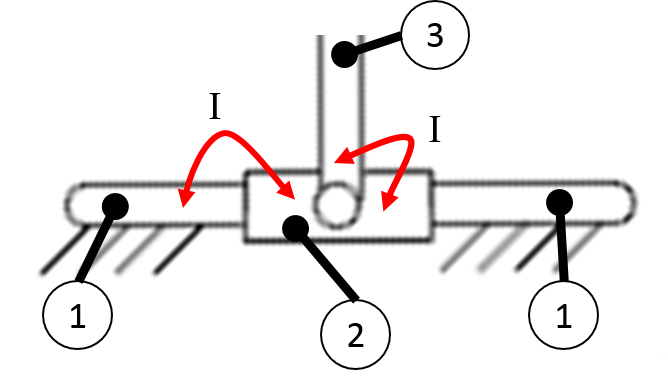
The slider block is modeled as an additional link, with two degree I joints.
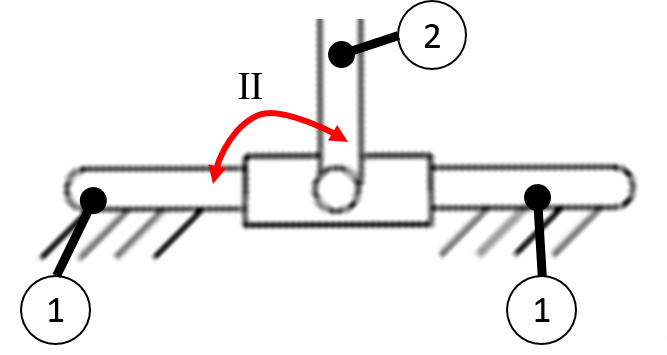
The block is not counted as a link, but one degree II joint is counted.
Joints with more than two links#
A joint connecting \(k\) links counts as \(k-1\) simple joints. When more than two bars meet at a single joint, we have to analyze how they move with respect to each other. For example:
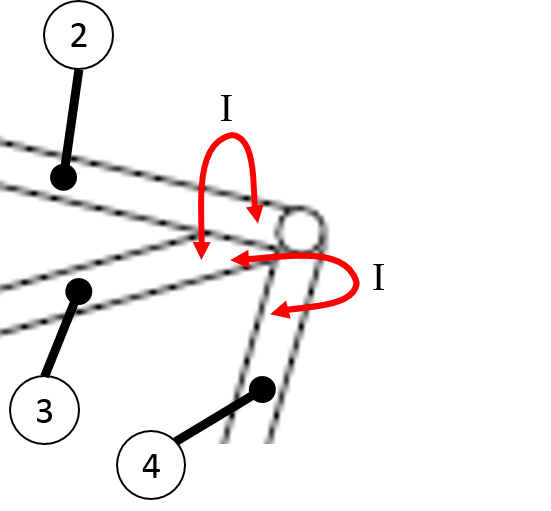
Articulation with three bars.
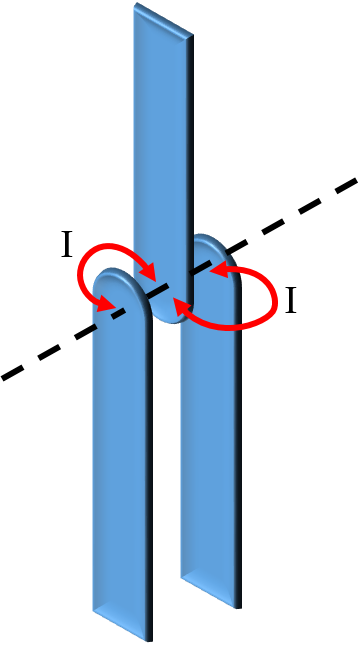
There are two revolute joints (degree I).
Exceptions and problematic cases#
The Grübler/Kutzbach formula can fail in certain cases:
Redundant constraints: Sometimes a mechanism has more constraints than strictly needed to produce a determinate motion. The formula may predict 0 or fewer d.o.f., yet the mechanism still moves because of a very specific geometry (e.g., a five-bar parallelogram mechanism). These extra constraints are not independent.
Passive or local degrees of freedom: Some mechanisms have local motions (such as a ball rolling in a track) that do not affect the mechanism’s overall motion. The formula may count these d.o.f., leading to an incorrect result for the main mobility.
Numerical methods criterion#
When using multibody formulations for machine and mechanism analysis, there exists a more advanced alternative to Grübler’s method:
Based on the Jacobian matrix of the constraints.
It works for both 2D and 3D mechanisms.
It detects singular configurations (Grübler fails!).
This method will not be studied in the present introductory course.