Six-bar linkage#
Most of the popular six-bar mechanisms are built from kinematic inversions of two different kinematic chains: Stephenson’s and Watt’s. These mechanisms are important because they can generate more complex motions than four-bar ones, such as paths with straight-line segments or motions with temporary stops (dwell).
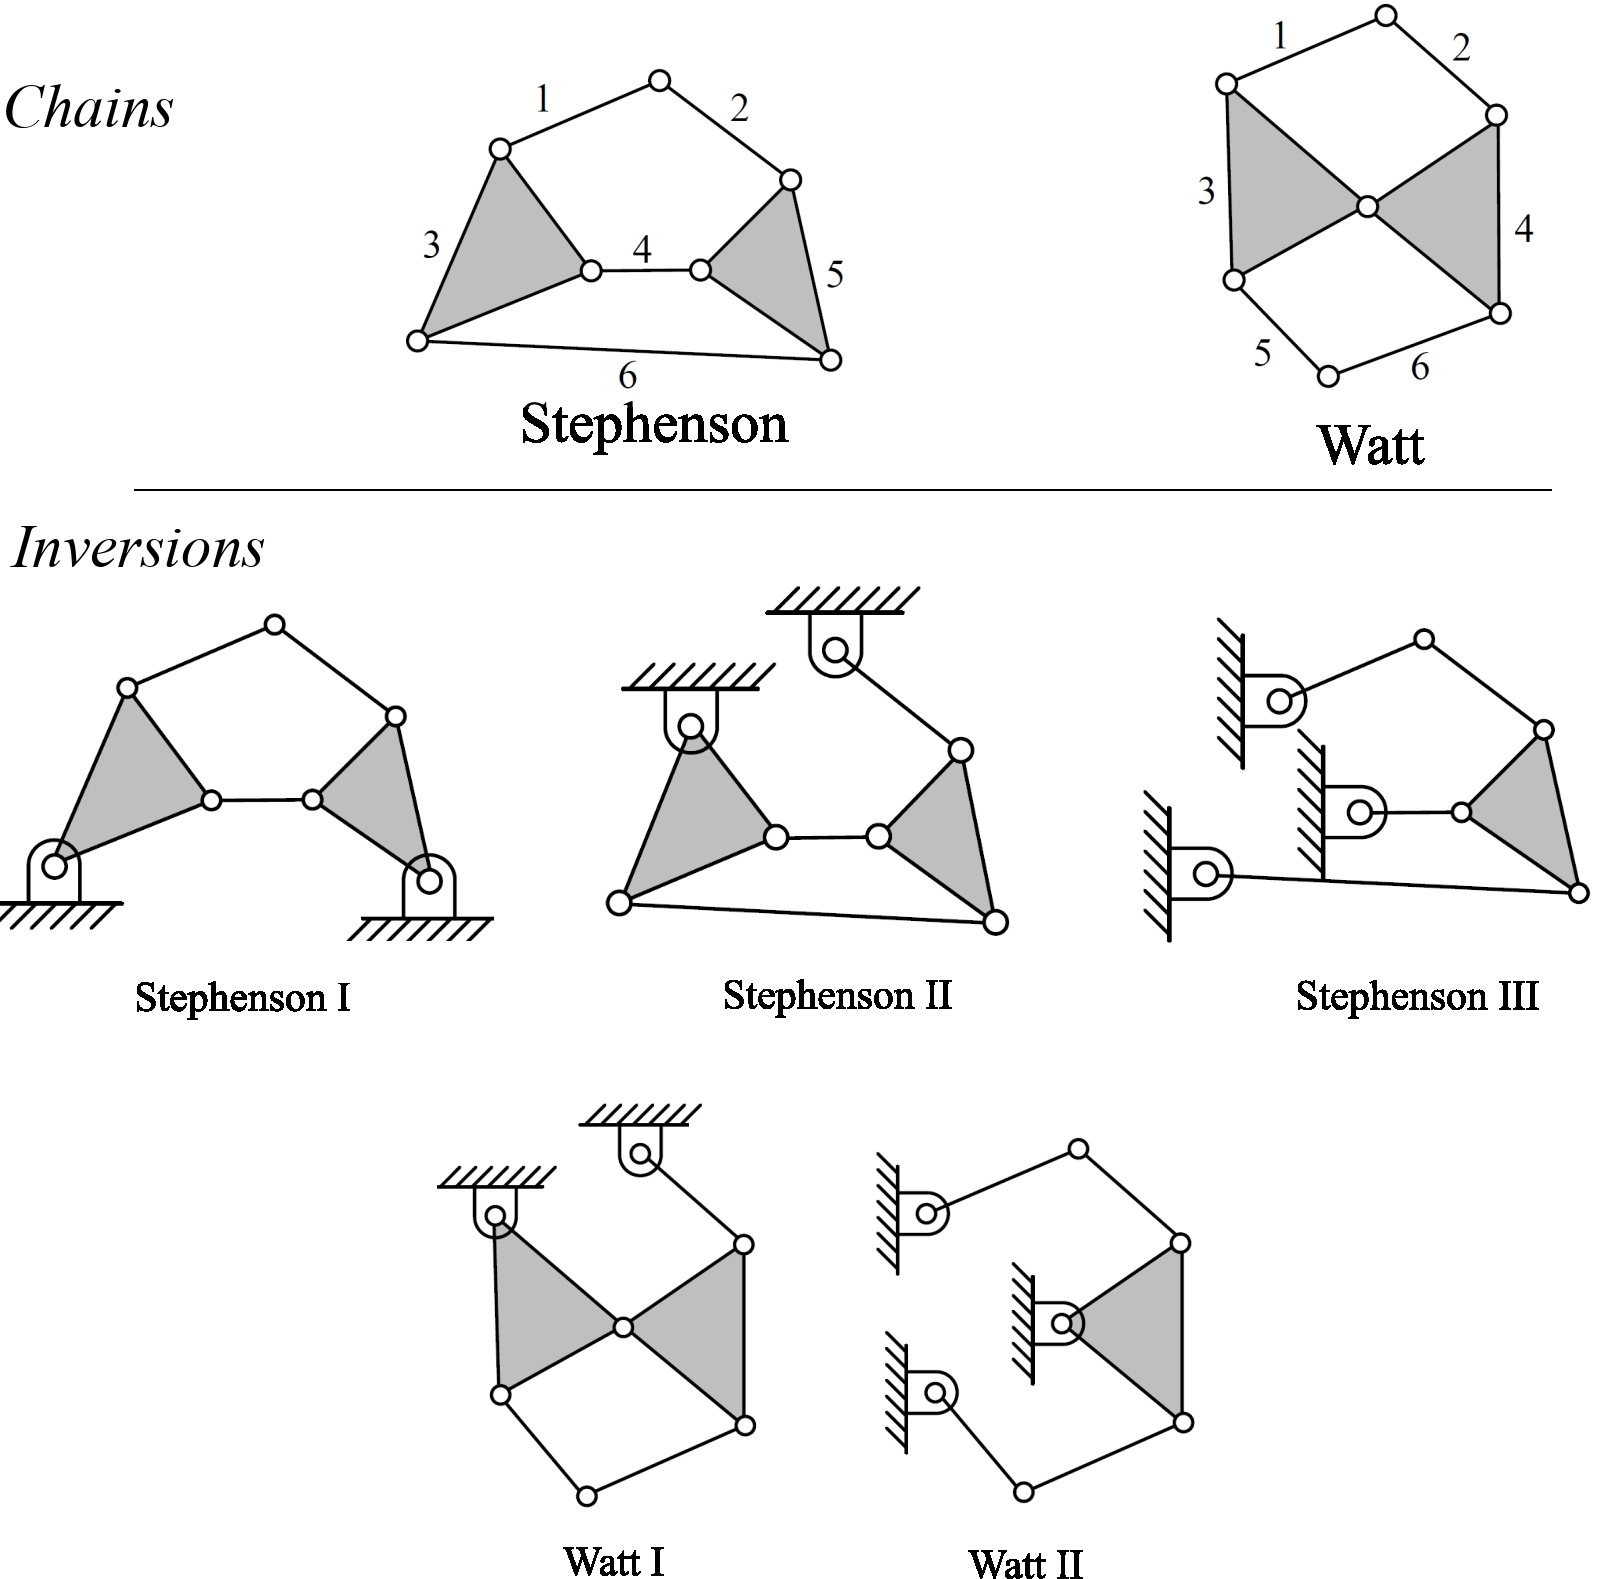
A simulation of the resulting mechanisms can be seen in the following applets.
Stephenson mechanism#
Drag the point A to see how each inversion of the mechanism moves:
Watt mechanism#
Drag the point A to see how each inversion of the mechanism moves: