Four-bar linkage#
The four-bar linkage, or simply four-bar mechanism, is one of the most common mechanisms:
Four rigid bodies: #1 (ground), and three moving bars #2, #3, and #4.
Two moving points: A and B.
Two fixed points: \(O_2\) and \(O_4\).
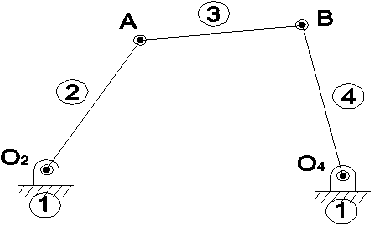
It features one degree of freedom: moving one bar fully determines the position of all other bars. The same applies to velocities and accelerations: fixing the velocity or acceleration of one “input” bar, we can compute the corresponding values for the whole mechanism.
Bar names#
Crank: A bar connected to the ground that can undergo complete revolutions. We may have 0, 1, or 2 cranks in a four-bar mechanism.
Rocker: A bar connected to the ground that can only oscillate back and forth. We may have 0, 1, or 2 rockers.
Connecting rod or coupler: The bar that is not connected to the ground.
Grashof’s law#
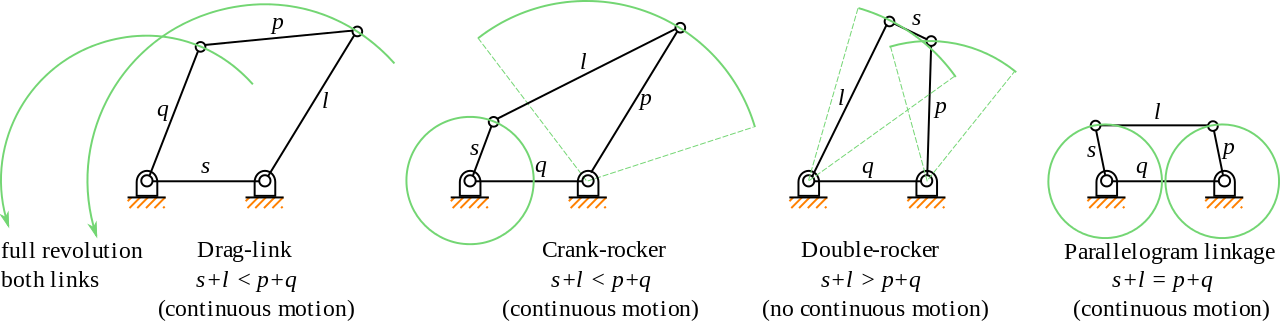
For at least one of the links connected to the ground to be a crank, the sum of the lengths of the shortest (S) and longest (L) links must not be greater than the sum of the other two (P and Q).
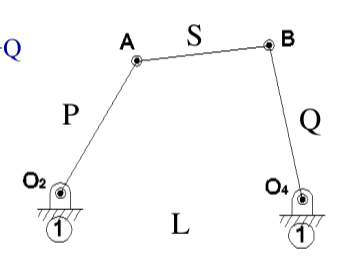
Types of Grashof mechanisms: Depending on which link is chosen as the ground (fixed link), a Grashof chain can give rise to three different mechanism types:
Crank-rocker: Obtained when the link adjacent to the shortest link (S) is fixed. Link S acts as a crank (turns 360°) and the output link oscillates as a rocker.
Double-crank (or drag-link): Obtained when the shortest link (S) itself is fixed. Both the input and output links can turn 360°.
Double-rocker: Obtained when the link opposite the shortest one (S) is fixed. Both links pivoted to the ground oscillate, and neither can complete a full turn.
If the condition is not met (\(S+L > P+Q\)), the mechanism is non-Grashof, and it will always be a double-rocker, regardless of which link is fixed.
Example of a case with a double crank:
To find out more details on the kind of motion, there is a criterion to find out whether there are one or two cranks. First, we name bar lengths according to their role:
\(a\): Input bar (left)
\(b\): Output bar (right)
\(g\): Ground bar
\(h\): Connecting rod (top)
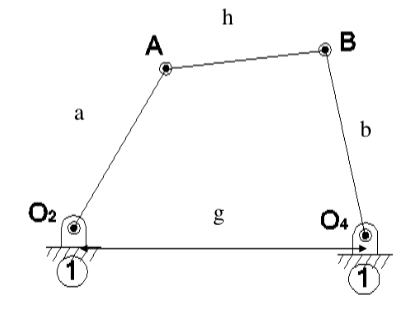
Then, we may have 8 different situations (bar names are shown for both the picture above and the interactive demo further below). The following test variables are defined:
Possible outcomes:
Linkage type |
\(T_1\) |
\(T_2\) |
\(T_3\) |
|
|---|---|---|---|---|
1 |
Crank-rocker |
+ |
+ |
+ |
2 |
Rocker-crank |
+ |
- |
- |
3 |
Double-crank |
- |
- |
+ |
4 |
Double-rocker |
- |
+ |
- |
5 |
Double-rocker |
- |
- |
- |
6 |
Double-rocker |
+ |
+ |
- |
7 |
Double-rocker |
+ |
- |
+ |
8 |
Double-rocker |
- |
+ |
+ |
Try it yourself!#
Change the bar lengths in this interactive demo (source) to verify Grashof’s law:
Some tips:
Drag the slider \(\theta_2\)
The lengths \(a\), \(b\), \(g\), and \(h\) above are named \(r_2\), \(r_4\), \(r_1\), and \(r_3\) in the GeoGebra model, respectively.
Example of double-crank: \((r_1,r_2,r_3,r_4)=(5,7,8,9)\). \(T_1=5+8-7-9=-\), \(T_2=9+5-7-8=-\), \(T_3=9+8-5-7=+\) (
--+).